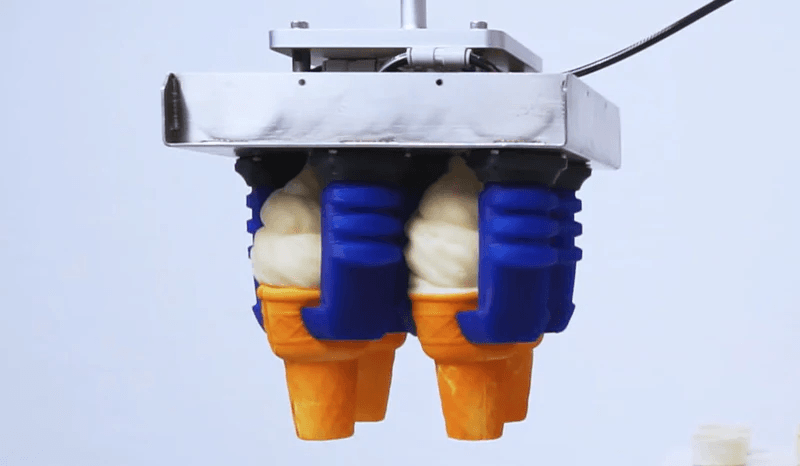
Advanced Soft Robotic Gripping for Flexible Industrial Automaton
The demand for flexible automation is increasing as industries move toward faster production, shorter product cycles, and more customized manufacturing. Robots are now expected to handle products that may differ in size, shape, weight, texture, and orientation. Traditional rigid gripping tools can be highly effective in stable production environments, but they may require frequent tooling changes when product characteristics vary.
Soft robotics provides an alternative approach. By combining flexible materials, pneumatic actuation, vacuum technology, magnetic mechanisms, sensors, and intelligent controls, modern robotic systems can achieve a greater level of adaptability. A Best Soft Gripper Manufacturer can develop end-of-arm solutions that help robots handle objects with greater flexibility while maintaining reliable production performance.
From food processing and packaging to manufacturing and warehouse automation, soft gripping technology is opening new opportunities for robotic handling.
Understanding Soft Robot Gripper Technology
A Soft Robot Gripper is an end-effector designed to grasp products using flexible and compliant structures. Rather than depending exclusively on rigid mechanical jaws, the gripper can deform when it makes contact with an object.
This allows the gripping surface to adapt to different product geometries. A flexible finger may bend around a rounded object, adjust to an uneven surface, or provide a broader contact area than a rigid jaw.
Soft Robot Gripper systems can use pneumatic, vacuum, electric, cable-driven, or hybrid actuation. The selection depends on the application and the required gripping performance.
For industries handling several product types, adaptable gripping can reduce the need for dedicated tooling.
What Is a Soft Robotics Gripper?
A Soft Robotics Gripper (https://softrobotgripper.com/) uses compliant components to interact with objects. Its flexible construction allows the gripping mechanism to change shape during operation.
This flexibility can be particularly valuable when products are fragile or irregular.
For example, a conventional rigid jaw may apply pressure at two specific points. A Soft Robotics Gripper can use flexible fingers that wrap around the object, creating multiple contact areas.
The result can be a more adaptable gripping process.
Soft robotics also provides opportunities for lightweight end-effectors, which can be beneficial when the gripping system is installed on smaller robotic arms or collaborative robots.
Soft Finger Robotics for Adaptive Handling
Soft Finger Robotics focuses on flexible robotic fingers capable of controlled deformation.
Many soft fingers are designed with internal chambers that respond to pneumatic pressure. When air enters the chambers, the flexible structure bends.
The amount and direction of bending can be controlled through the geometry of the actuator and the supplied pressure.
Multiple soft fingers can work together to form a complete gripper.
This design is useful for objects that have complex shapes because the fingers can adapt during contact instead of following a single rigid movement.
Benefits of Soft Finger Technology
Soft fingers can provide several advantages for automated handling.
They can adapt to irregular products without requiring precise mechanical alignment.
They can provide compliant contact that is useful when handling delicate objects.
They can also accommodate product variations on the same production line.
The finger material and geometry can be customized for different applications. Softer materials may be selected for delicate products, while stronger materials can be used when greater durability is required.
The flexibility of soft fingers makes them a valuable option for advanced robotic manipulation.
Working With a Best Soft Gripper Manufacturer
A Best Soft Gripper Manufacturer should evaluate the complete application before recommending a product.
The manufacturer may need information about product dimensions, weight, surface properties, operating speed, production volume, and environmental conditions.
The robot's payload and mounting configuration are also important.
A properly selected gripper should provide enough holding force while remaining compatible with the robotic system.
Customization may also be required. Finger length, shape, material, gripping surface, actuator configuration, and mounting components can all influence performance.
Application testing with actual products can help determine whether a particular design is suitable.
Role of a Soft Robotics Solutions Supplier
A Soft Robotics Solutions Supplier can help businesses move from individual components toward complete robotic gripping solutions.
An automation project may require grippers, pneumatic systems, vacuum generators, sensors, valves, tubing, controllers, mounting hardware, and software integration.
A solutions-focused supplier can evaluate the production process and determine which combination of technologies is most appropriate.
Technical assistance can also be valuable during installation and commissioning.
Long-term support, replacement components, maintenance guidance, and troubleshooting can help maintain reliable operation.
Robot Soft Gripper for Manufacturing
A Robot Soft Gripper can be used for many manufacturing tasks.
Robotic arms can use soft gripping tools to load and unload machines, move components between stations, position parts during assembly, and transfer products to packaging areas.
The flexibility of the gripping mechanism can be useful when components have varying geometries.
Soft grippers can also be used where rigid contact could damage a surface.
Manufacturers can integrate these systems with vision and sensors to improve positioning and gripping accuracy.
Robot Vacuum Gripper Technology
A Robot Vacuum Gripper holds objects through vacuum pressure.
The system typically includes suction cups or a flexible suction surface connected to a vacuum source.
When the suction surface contacts the product, air is removed from the contact area. This creates a pressure difference that generates holding force.
Vacuum gripping can be fast and effective when the object has an appropriate surface.
Flat cartons, sheets, panels, containers, and packaging products are common examples of objects that may be suitable for vacuum handling.
The vacuum level should be monitored to ensure that the object remains securely attached during movement.
Robot Suction Gripper Applications
A Robot Suction Gripper can be designed with one or multiple suction points.
Multiple cups can help distribute the load across larger products.
The suction cups may also be positioned according to the product's geometry.
For warehouse automation, a suction gripper can pick packages from conveyors or storage bins.
For manufacturing, it can move sheets, panels, containers, and components with suitable surfaces.
In packaging, suction systems can rapidly transfer cartons, trays, and other products.
The correct suction cup material and design depend on the surface and environmental conditions.
Soft Gripper and Vacuum Technology Together
Soft fingers and suction systems do not necessarily have to be used separately.
A hybrid robotic end-effector can combine flexible fingers with vacuum suction.
The suction mechanism can provide primary holding force while the soft fingers stabilize the object.
Alternatively, the flexible fingers can pick an irregular object while a small suction element provides additional retention.
Combining gripping technologies can make the robotic tool more versatile.
This approach is especially useful when a production line handles several different product categories.
Pneumatic Magnetic Gripper Technology
A Pneumatic Magnetic Gripper (https://softrobotgripper.com/collections/srt-scb-pneumatic-control-module) combines pneumatic movement with magnetic holding capabilities.
Magnetic gripping is generally intended for suitable ferromagnetic materials. Pneumatic components can control the position or engagement of the magnetic mechanism.
This type of gripper can be useful in metal-processing and manufacturing applications.
For example, a robotic system may need to move steel components between production stages.
The gripping solution must be selected according to the material, object thickness, weight, surface condition, and required holding force.
Magnetic technology can provide an efficient alternative when vacuum or mechanical gripping is not appropriate.
Soft Robotics in Food Handling
Food handling presents unique automation challenges.
Products may be fragile, soft, wet, irregularly shaped, or inconsistent in size.
A Soft Robotics Gripper can provide compliant contact that adapts to these characteristics.
Soft fingers may be used to pick fruits, vegetables, bakery products, seafood, and other delicate items.
The gripper must be designed according to hygiene and cleaning requirements.
Materials used in food applications should be appropriate for the intended environment, while the design should minimize areas where contamination could accumulate.
Agriculture and Harvesting Automation
Agricultural products naturally vary in shape and size, making them challenging for conventional automation.
Soft Finger Robotics can provide a flexible gripping interface for harvesting and handling.
A robotic system can use cameras to identify a product and then position flexible fingers around it.
The fingers can deform during contact and create a secure grip.
Soft robotic systems may also be used for sorting, grading, packing, and transferring crops.
The main objective is to combine reliable automation with careful product handling.
Packaging and Distribution
Packaging facilities often operate at high speeds and process many different products.
A flexible robotic gripping system can help automate repetitive picking and placing tasks.
Robot Suction Gripper systems can rapidly move packages with suitable surfaces, while Robot Soft Gripper technology can handle products that require more adaptive contact.
Vision systems can help robots identify the location and orientation of products before picking.
This can improve automation efficiency in dynamic packaging environments.
Warehouse Picking With Adaptive Grippers
Warehouse robots must often handle products that were not designed specifically for robotic manipulation.
Items can have different packaging materials, shapes, weights, and surfaces.
A Robot Vacuum Gripper can be useful for boxes and other products that provide a suitable vacuum surface.
Soft grippers can be better suited to irregular products.
Combining vision with adaptive gripping allows a robot to select different strategies depending on the object.
This approach can help improve the flexibility of automated warehouse picking systems.
Sensors for Better Gripping Performance
Sensors are becoming increasingly important in robotic gripping.
Pressure sensors can monitor pneumatic systems.
Vacuum sensors can identify whether a suction cup has created an effective seal.
Force and tactile sensors can detect contact between fingers and objects.
Position sensors can track finger movement.
When this information is connected to a robot controller, the system can respond to changes during the gripping process.
This can help prevent failed picks and improve overall reliability.
Artificial Intelligence and Soft Robotics
Artificial intelligence is expected to increase the capabilities of soft robotic systems.
A vision system can identify an object's location, size, and orientation.
AI software can analyze this information and determine an appropriate gripping position.
The robot can then select a gripping method based on the object.
For example, it could use a Robot Suction Gripper for a flat package or Soft Finger Robotics for an irregular product.
This type of intelligent decision-making can make robotic systems more flexible in unpredictable environments.
Factors to Consider When Selecting a Gripper
Selecting the right gripping technology requires careful evaluation.
Product weight is important because the gripper must provide enough holding force.
Product geometry determines whether fingers, suction, magnets, or another mechanism is most suitable.
Surface properties are particularly important for vacuum systems.
Production speed determines how quickly the gripper needs to operate.
Environmental conditions can influence material and component selection.
The robot's payload and available utilities should also be considered.
Businesses should evaluate the complete system rather than selecting a gripper based only on its advertised gripping force.
Customization for Specialized Applications
Standard gripping products can be suitable for many applications, but specialized tasks may require customization.
A manufacturer may modify finger length, material stiffness, chamber geometry, suction cup configuration, or mounting arrangements.
Custom gripping surfaces can also be developed for products with unusual textures or shapes.
Application testing is essential for customized systems.
Testing with actual products helps engineers evaluate gripping stability, cycle time, product damage, release behavior, and long-term durability.
Maintenance and Operational Reliability
Regular maintenance is essential for maintaining consistent gripping performance.
Soft fingers should be inspected for cuts, cracks, deformation, or excessive wear.
Pneumatic tubing and fittings should be checked for leaks.
Vacuum lines should be inspected for blockages or damaged connections.
Suction cups can wear over time and may require replacement.
Magnetic components should also be inspected when used in industrial handling applications.
Preventive maintenance can help reduce unexpected downtime.
The Future of Robotic Gripping
The future of gripping technology is likely to involve multifunctional robotic end-effectors.
A single tool may combine soft fingers, vacuum suction, magnetic holding, sensors, and intelligent control.
Advanced materials may allow flexible fingers to adjust their stiffness during operation.
Embedded sensors could provide real-time information about contact and gripping force.
AI-powered vision systems could help robots identify products and select appropriate gripping strategies automatically.
These developments can make robots more capable of operating in environments where product variation is high.
Conclusion
Soft robotic gripping is becoming an important technology for modern industrial automation. A Best Soft Gripper Manufacturer can provide flexible end-of-arm solutions designed to meet specific product and production requirements.
Soft Robot Gripper and Soft Robotics Gripper systems provide compliant handling, while Soft Finger Robotics offers flexible finger technology for irregular and delicate products. Robot Vacuum Gripper and Robot Suction Gripper systems provide efficient vacuum-based handling for suitable surfaces. Pneumatic Magnetic Gripper technology offers specialized handling capabilities for compatible metal components.
A dependable Soft Robotics Solutions Supplier can help businesses evaluate these technologies, integrate them with robotic equipment, and develop solutions suited to specific applications.
As industries demand greater flexibility and automation becomes more intelligent, robotic gripping systems will continue to evolve. Advances in materials, pneumatics, vacuum technology, magnetic systems, sensing, machine vision, and artificial intelligence will help robots handle an increasingly diverse range of products.
Soft robotics is therefore not simply an alternative to conventional gripping. It is an important technology for building adaptable automation systems capable of meeting the changing requirements of modern production.
Appreciate the creator